3D Plasma Cutting Robot for Vessel Heads and Shells
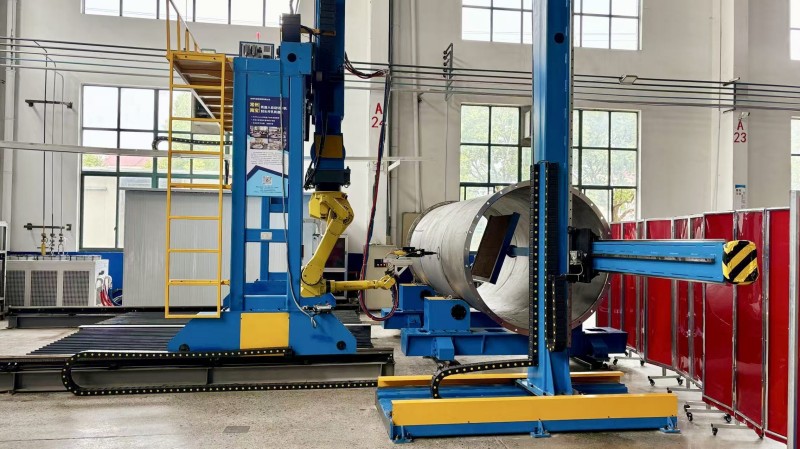
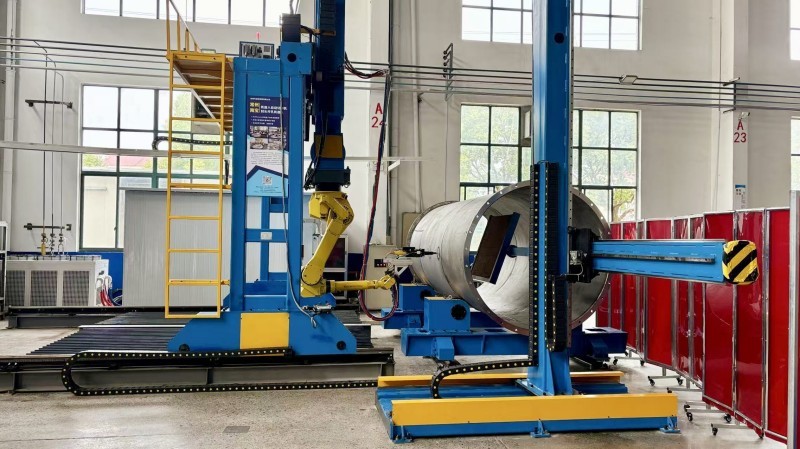
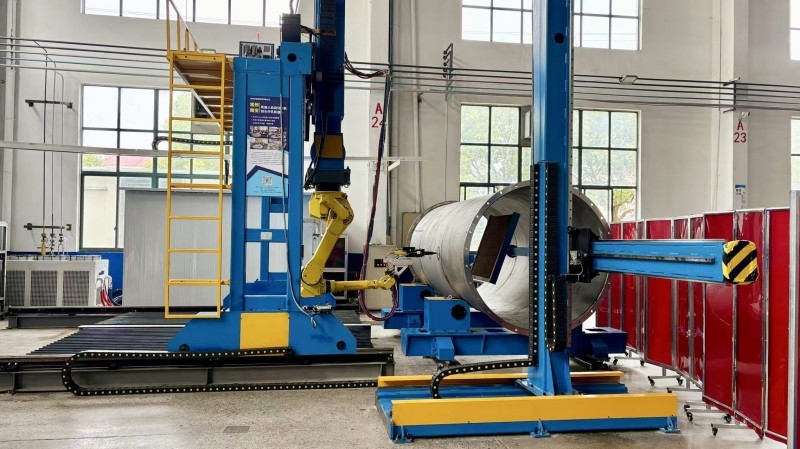
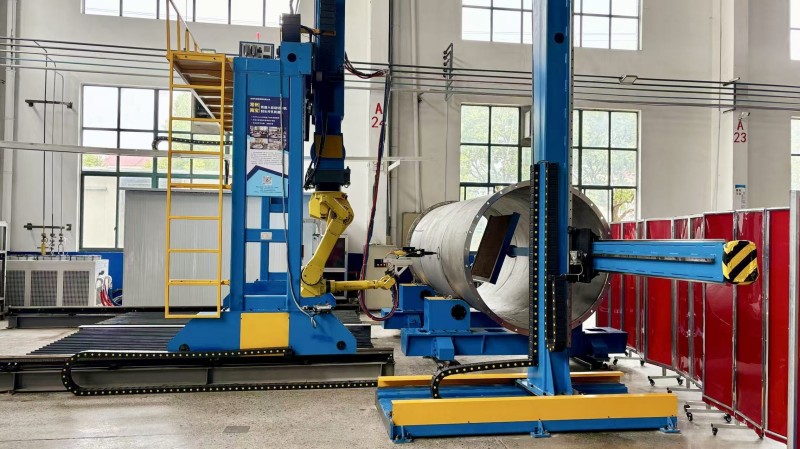
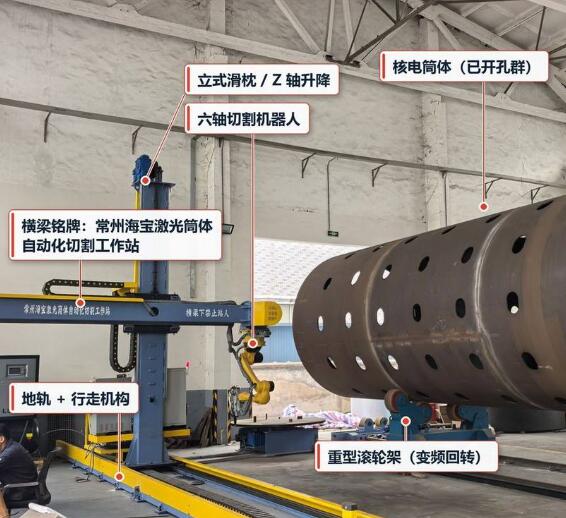
This haibao robot cutting workstation is configured for nozzle openings and weld preparation on vessel heads and shells. The reference delivery to Shanghai Qida Heavy Equipment combines a FANUC robot, external motion axes and an HBPRO-500 fine-plasma cutting system.
Equipment and application images
3D cutting robot for vessel head and shell openings |
Robotic cutting workstation delivered to Shanghai Qida |
haibao robot · PRESSURE VESSEL PRODUCTION EQUIPMENT
Robotic 3D Hole and Bevel Cutting for Pressure Vessels
This haibao robot cutting workstation is configured for nozzle openings and weld preparation on vessel heads and shells. The reference delivery to Shanghai Qida Heavy Equipment combines a FANUC robot, external motion axes and an HBPRO-500 fine-plasma cutting system.
Head and shell applications
The application covers spherical or elliptical heads and cylindrical shells with perpendicular, offset or inclined nozzle openings. Robot orientation and coordinated external motion allow the cutting tool to follow curved intersection contours and the specified bevel geometry.
Programming and workpiece location
The source describes offline programming and 3D simulation for generating the cutting path from part geometry. Workpiece datums and actual position must be established before cutting. Reviewing the model, torch approach and clearance reduces the need to develop every motion at the machine.
Configuration envelope
The reported application family includes heads up to 4,000 mm diameter and shells up to 3,000 mm diameter and 6,000 mm long. The source describes 6.5 m horizontal travel and 1 m vertical travel for the moving-axis arrangement. These values are configuration references and must be confirmed together with the actual fixture and reach study.
Define cutting quality by the finished opening
Hole dimensions, location, bevel angle, surface condition and any finishing allowance should be agreed before purchase. Cutting capability depends on material, thickness, hole size and bevel form. Representative trials and dimensional checks establish the usable production range; robot positioning specifications alone do not define finished-cut accuracy.
Configuration reference
| Robot | FANUC industrial robot with external motion axes |
| Cutting package | HBPRO-500 fine-plasma system in the reference delivery |
| Head diameter | Up to 4,000 mm, configuration dependent |
| Shell envelope | Up to 3,000 mm diameter × 6,000 mm length, configuration dependent |
| Programming | Offline programming and 3D path simulation |
| Thickness reference | Source lists up to 35 mm; material and bevel trials required |
| Acceptance | Finished opening and bevel measurements on agreed test pieces |
Discuss your application
Send a 3D model or head/shell drawing, nozzle schedule, material, thickness, bevel details and dimensional tolerances. We will review the robot envelope, external axes, fixture and sample-cut plan.
haibao robot
Shao Yicheng · Key Account Project Director · International Welding Engineer (IWE)
Email: masterhyper@163.com
Phone / WhatsApp: +86 177 5158 3908
Office: +86 519 8837 0688
Explore welding and cutting equipment · Read more application stories
INQUIRY
Categories
Latest News
Contact Us
Contact: Mr.Shao
Phone: 0086-17751583908
E-mail: 691043690@qq.com
Whatsapp:86-17751583908
Add: shanghai, China TianHe District, GuangZhou Num 899