Robotic Flanged Elbow Welding Cell
The haibao robot flanged-elbow cell brings circumferential seams, flange joints and lifting-lug welds into a coordinated fixture and robot sequence. Its reference installation at Jiangyin Dongxin serves pipe fitting production, including cooling-pipeline applications.
Equipment and application images
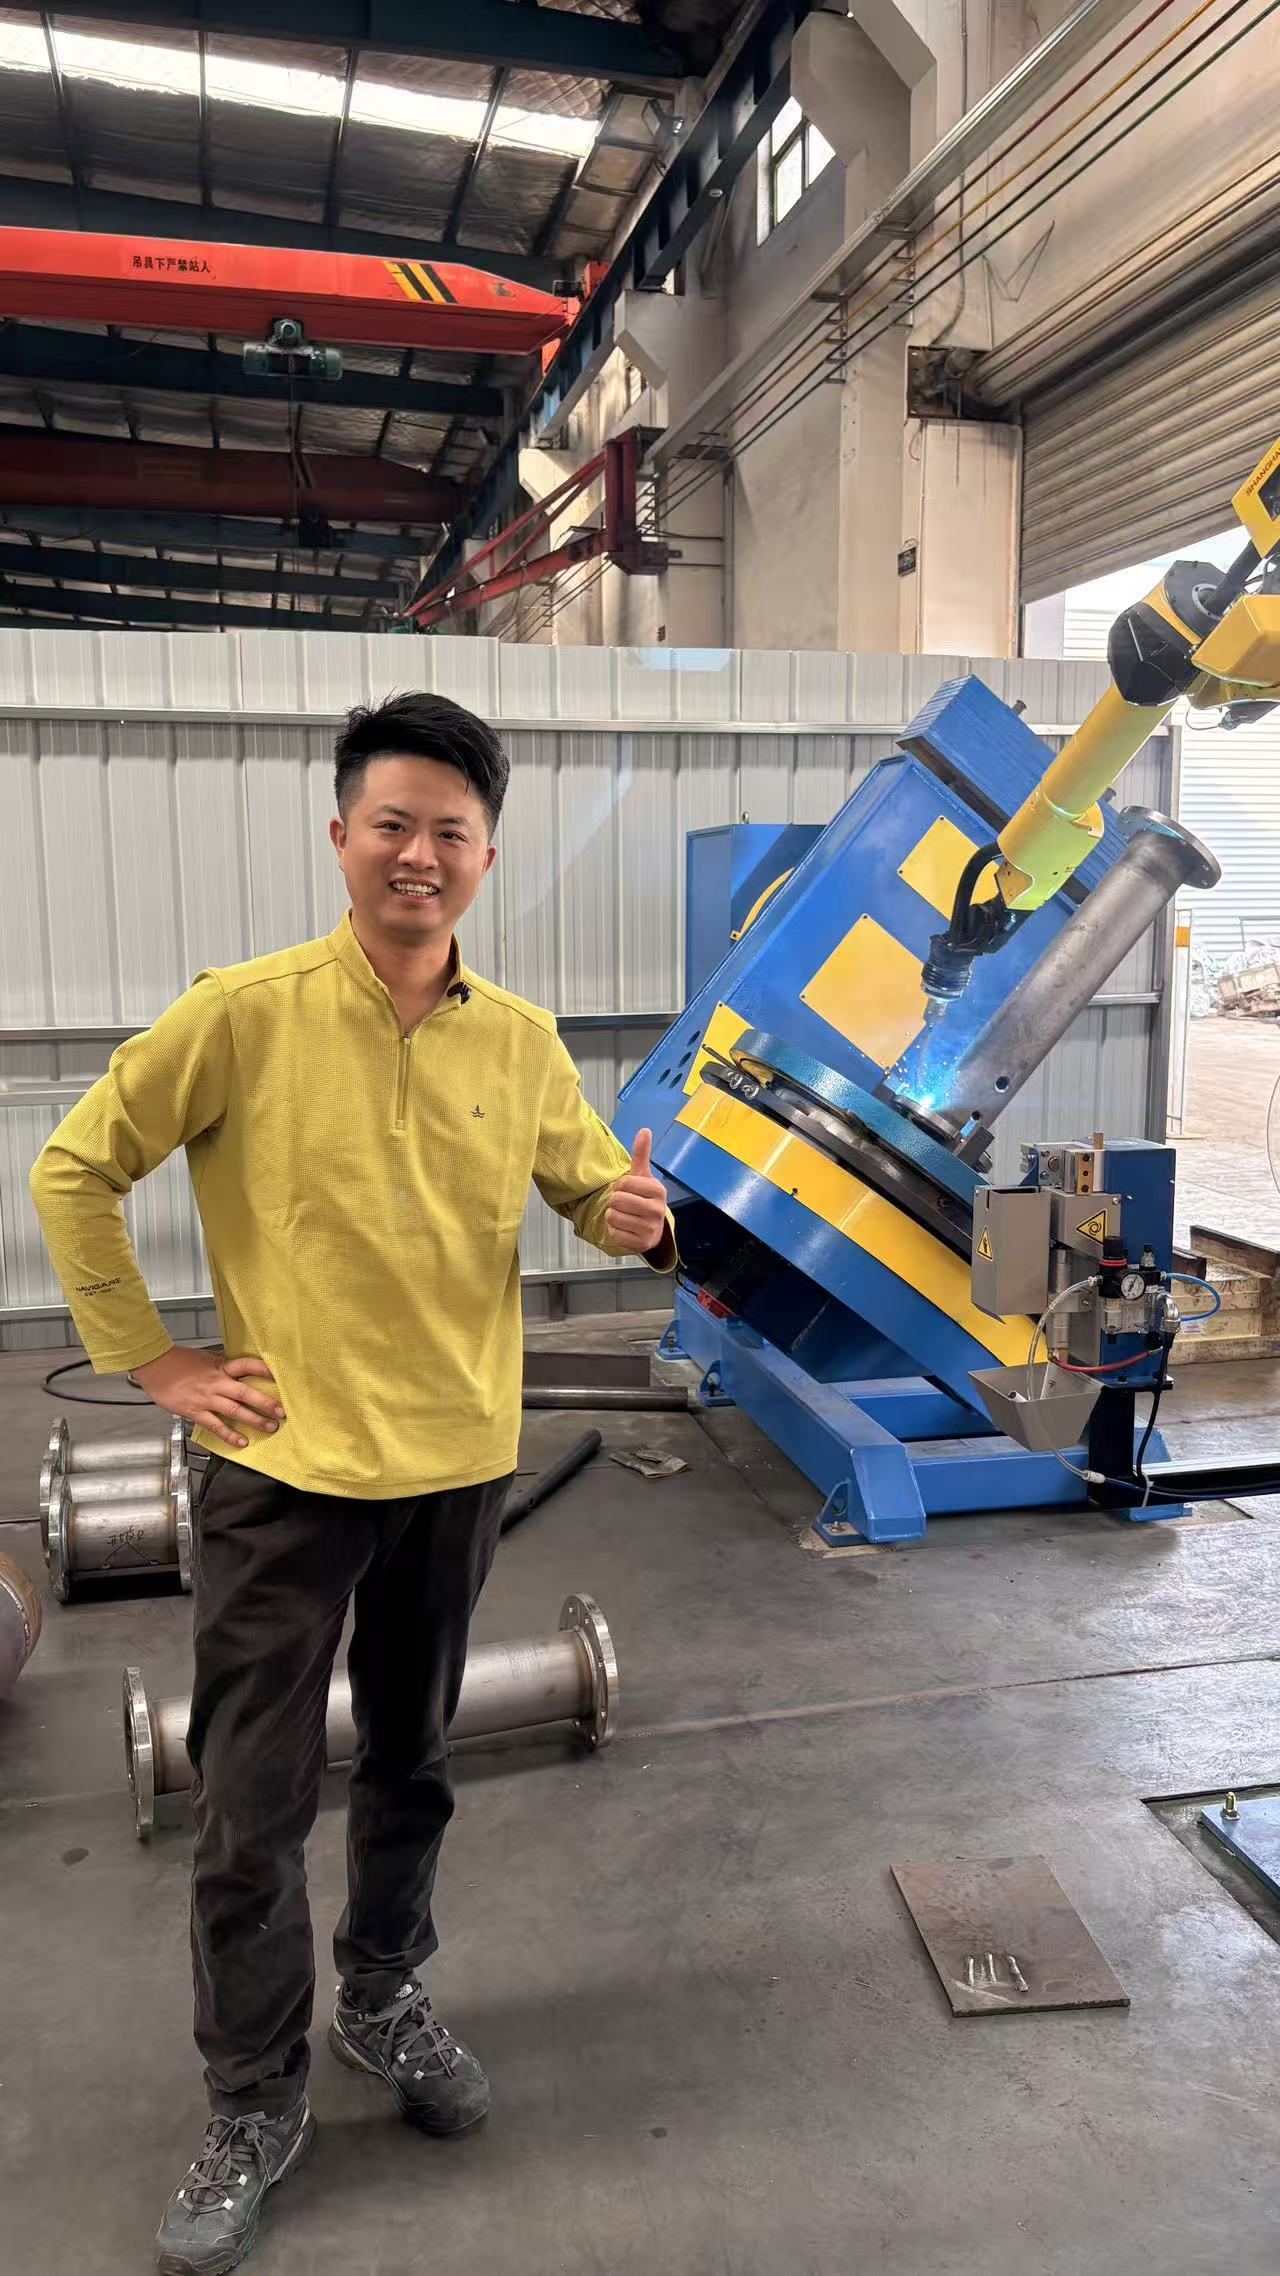
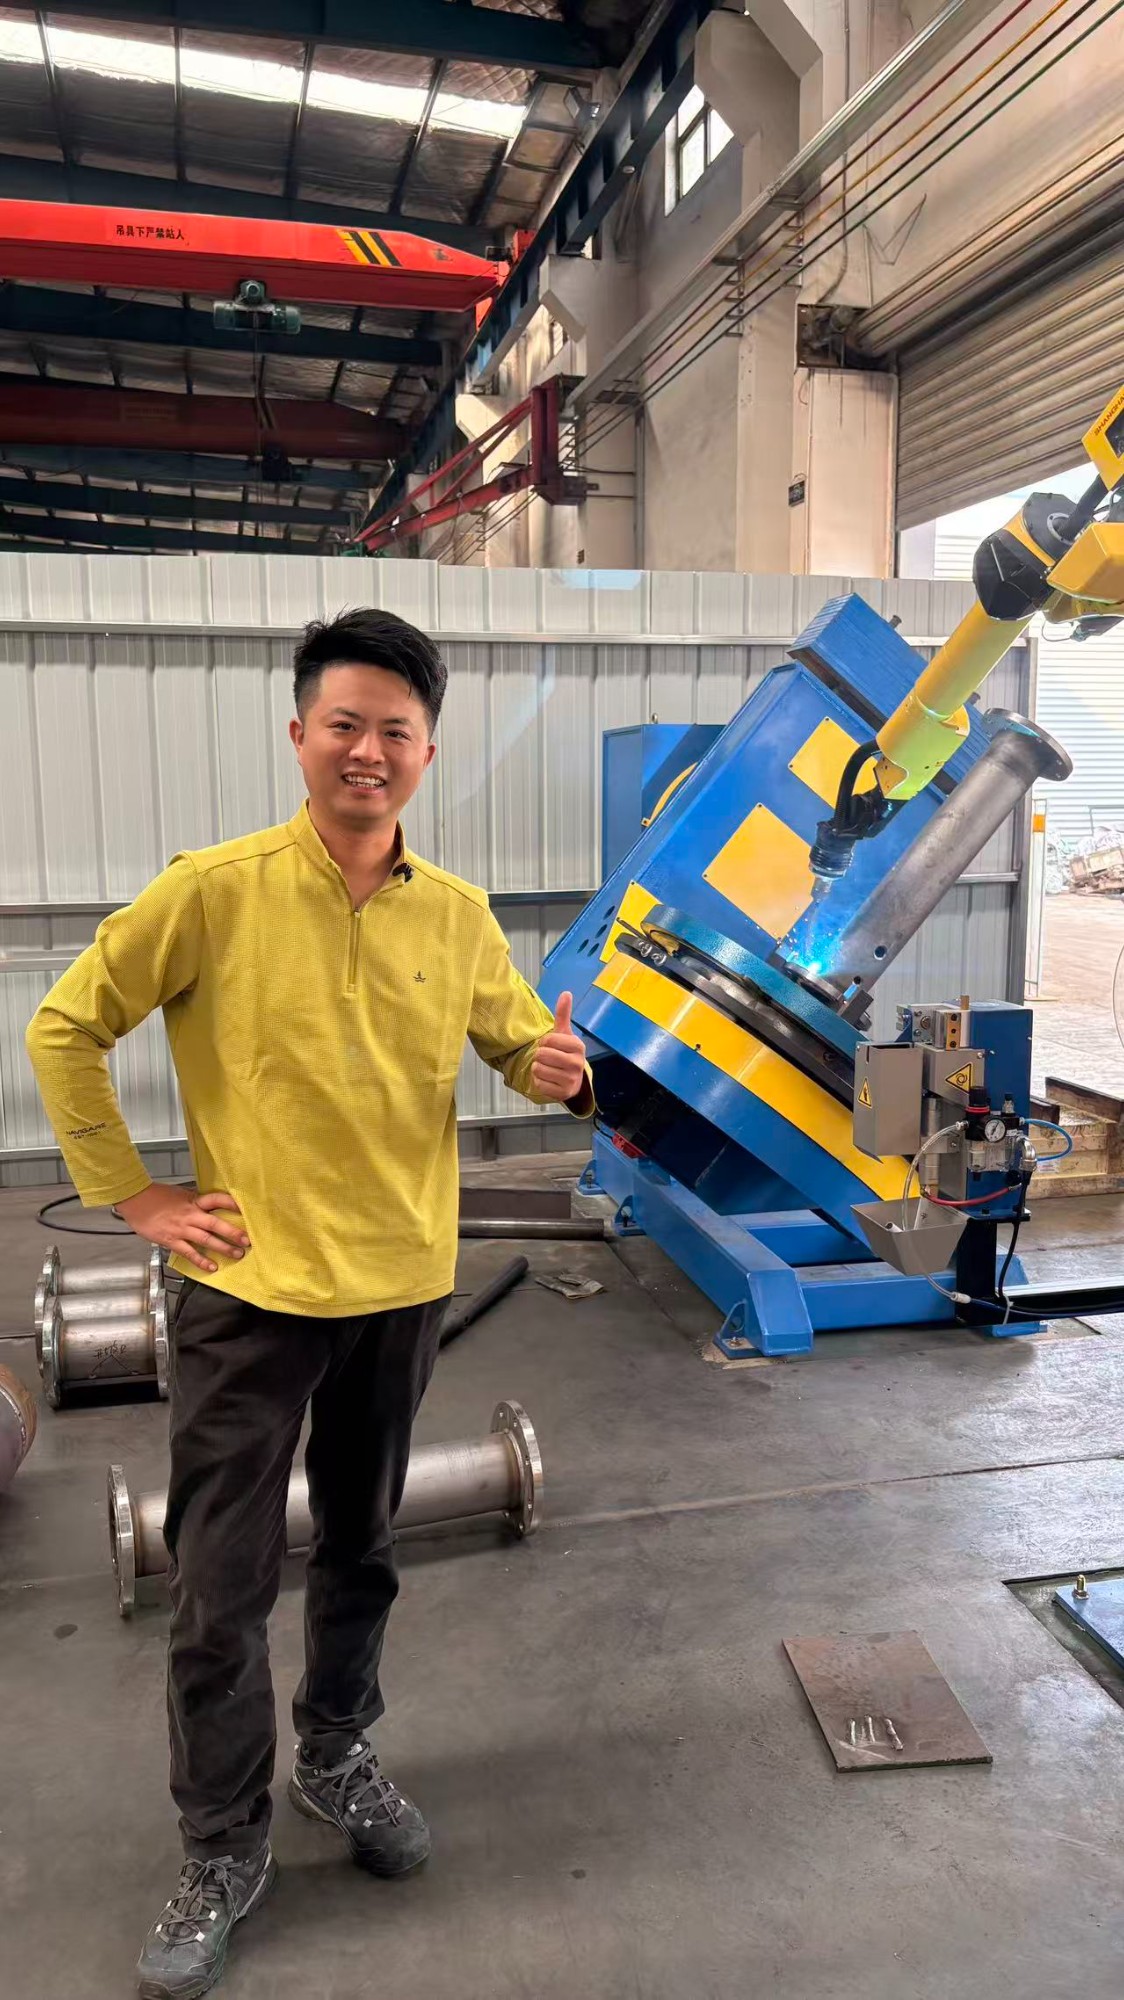
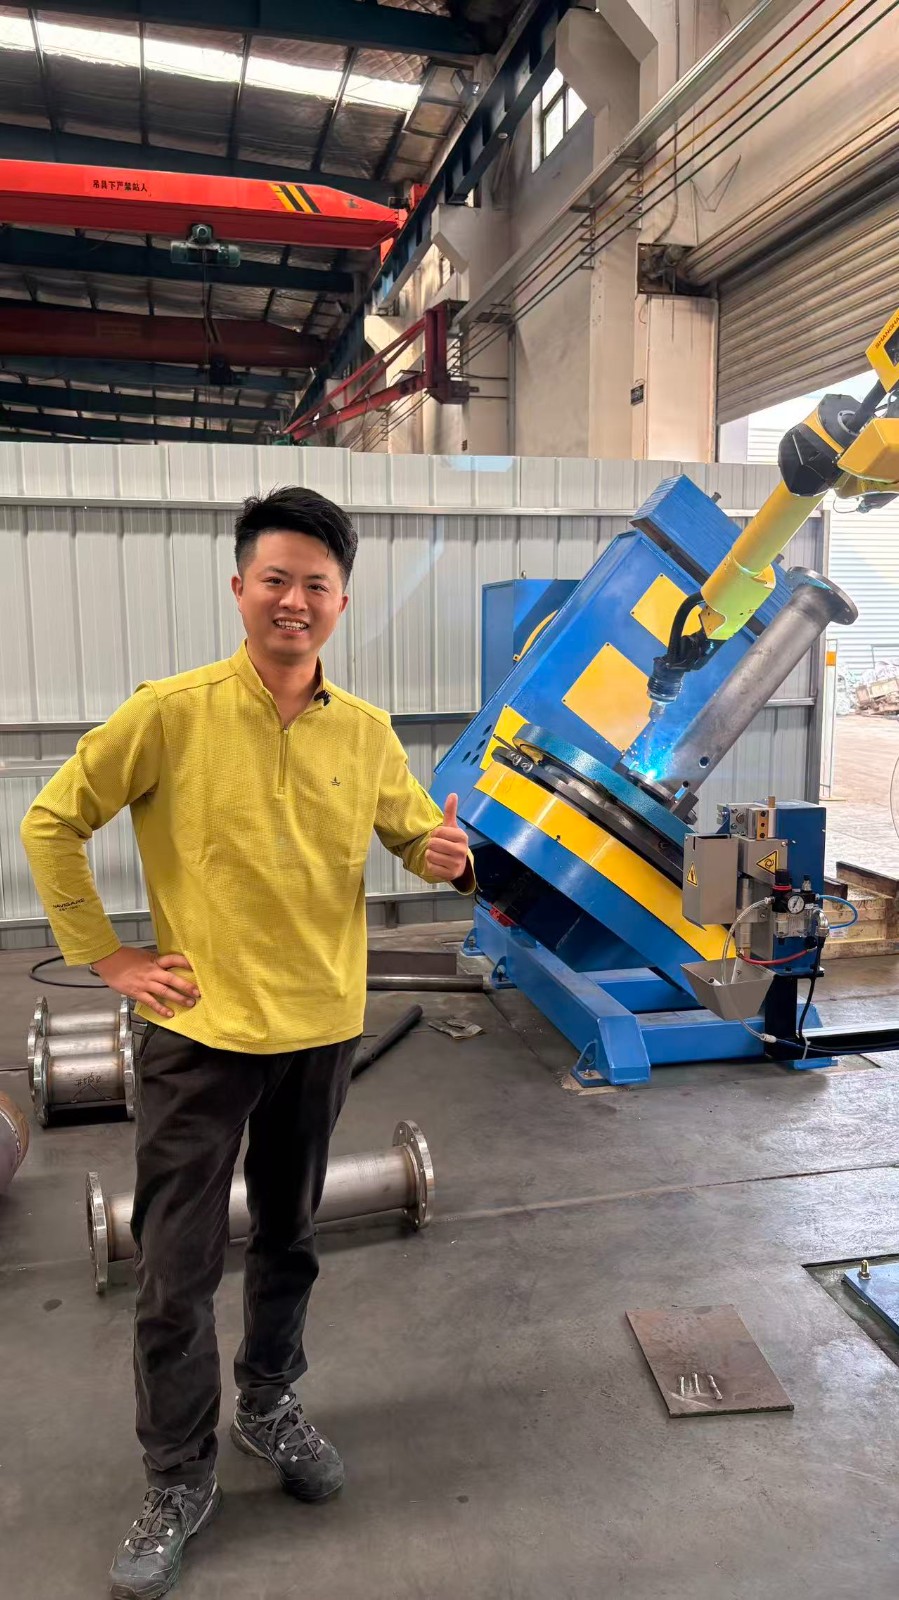
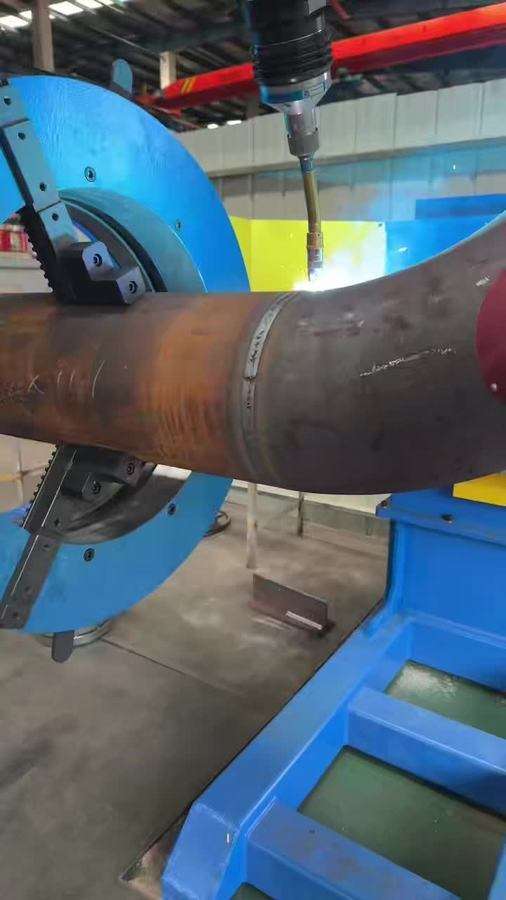
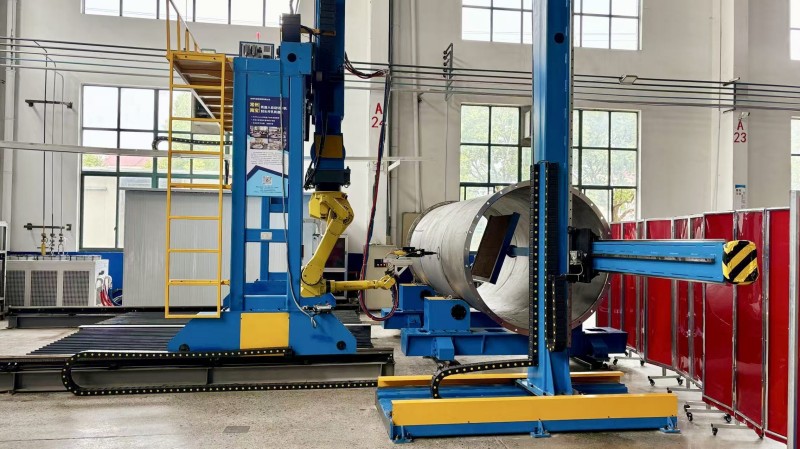
Flanged-elbow welding cell at the production site |
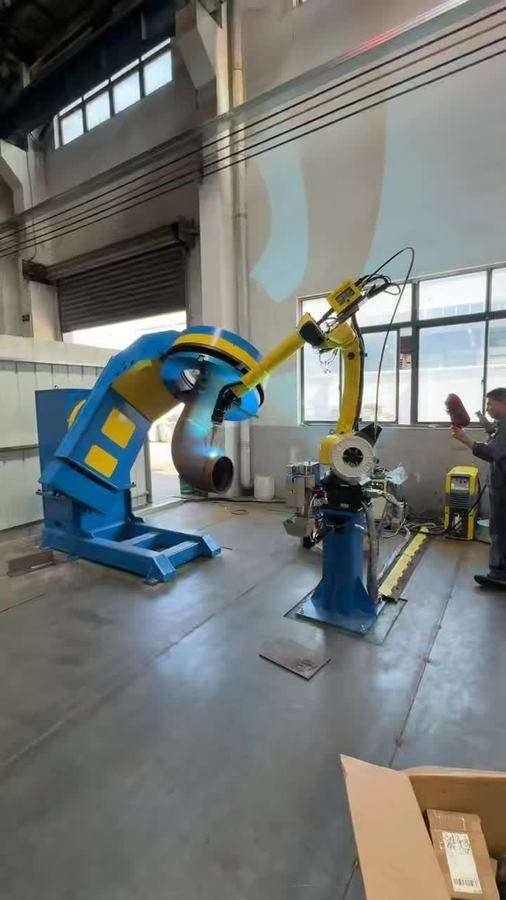
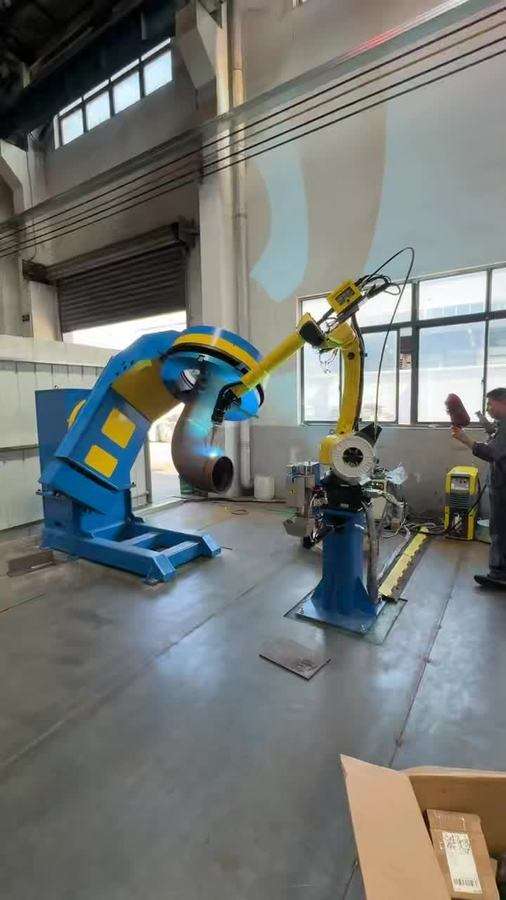
Robot and L-type positioner supporting an elbow assembly |
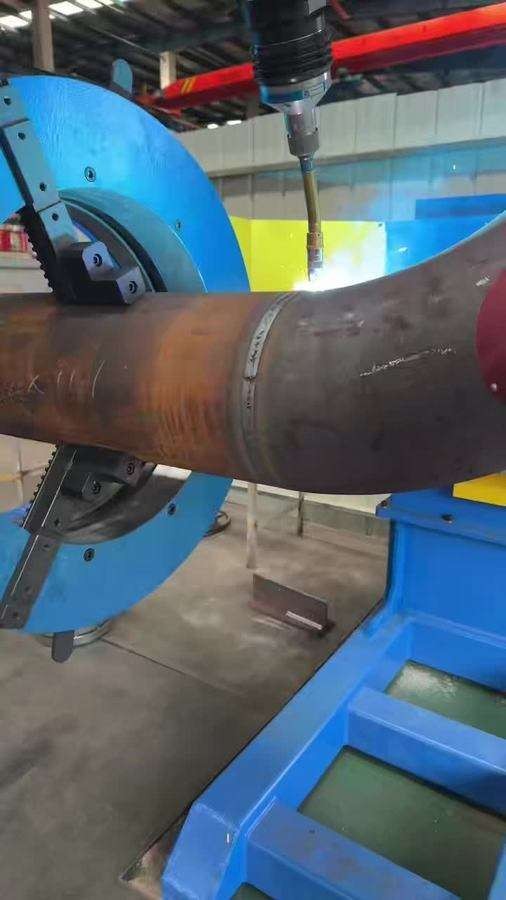
Circumferential welding on the pipe fitting |
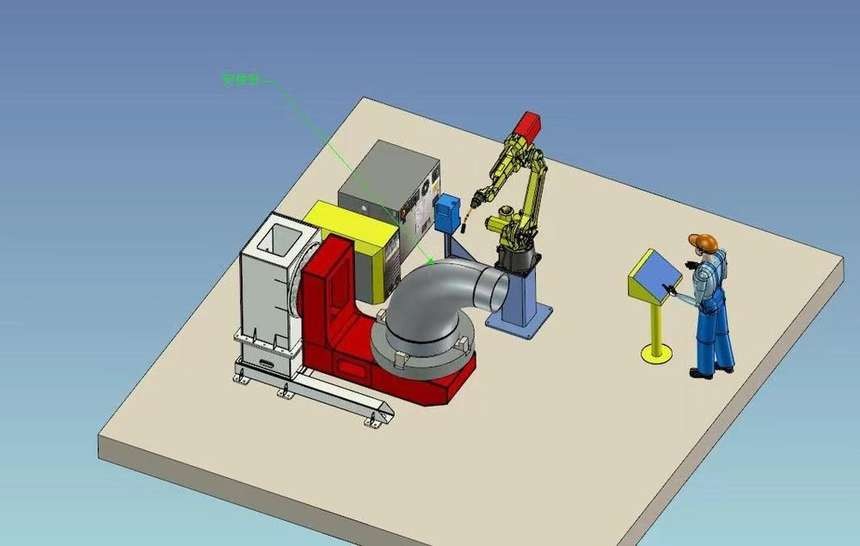
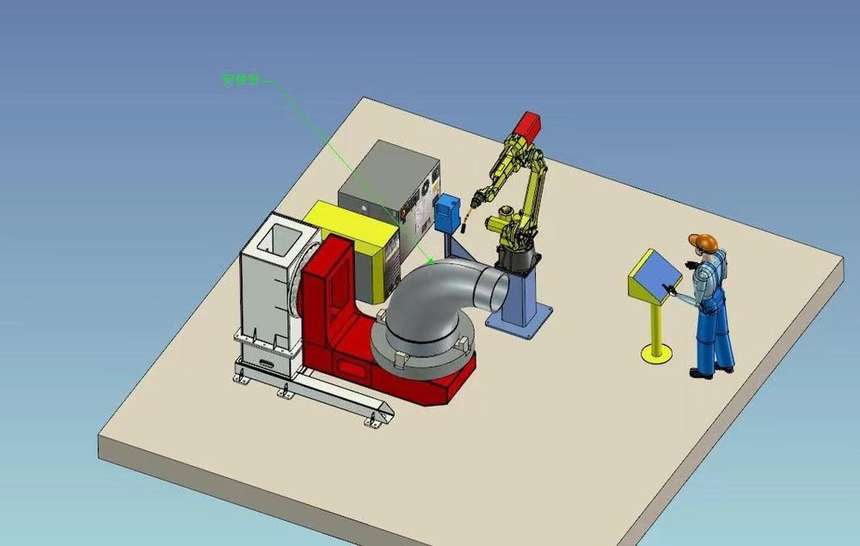
3D layout of the robotic elbow welding cell |
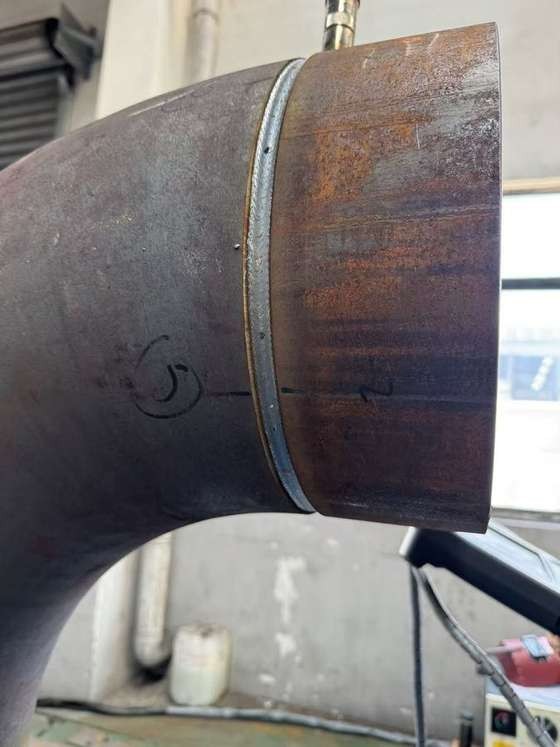
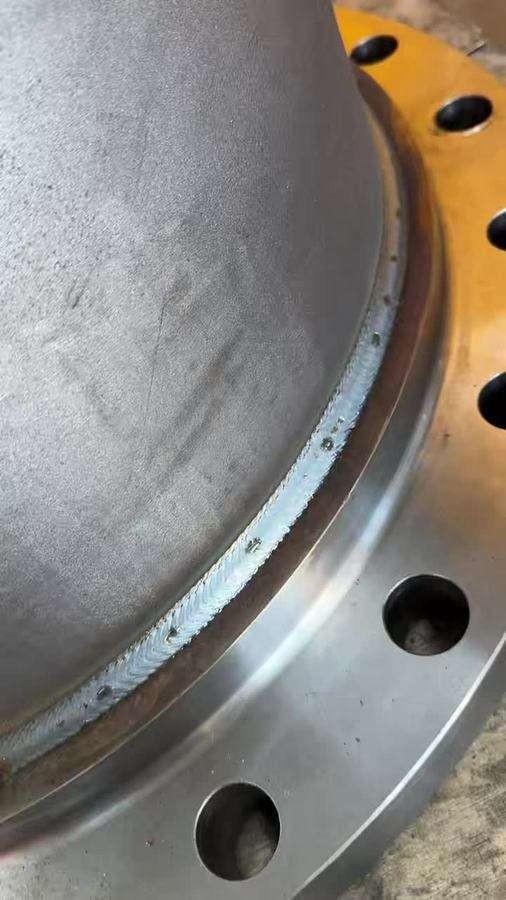
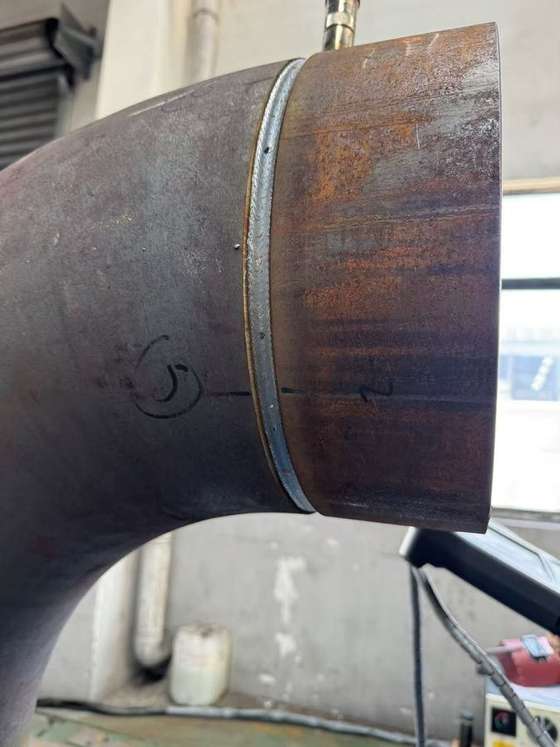
Elbow circumferential weld reference |
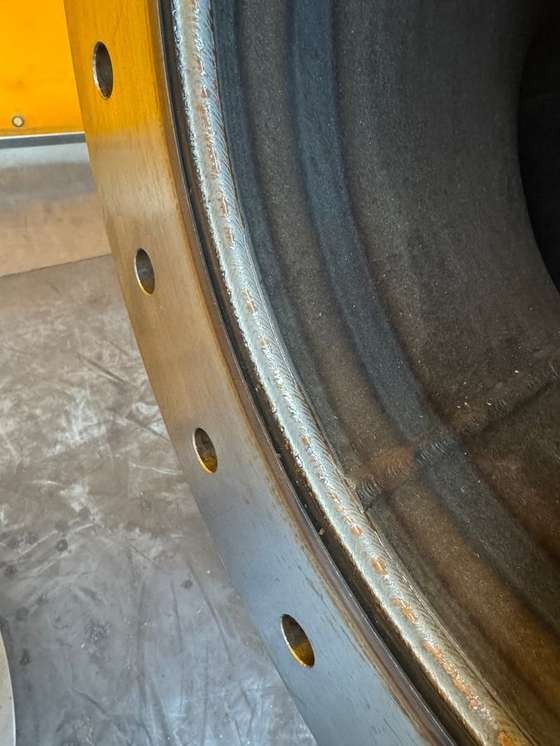
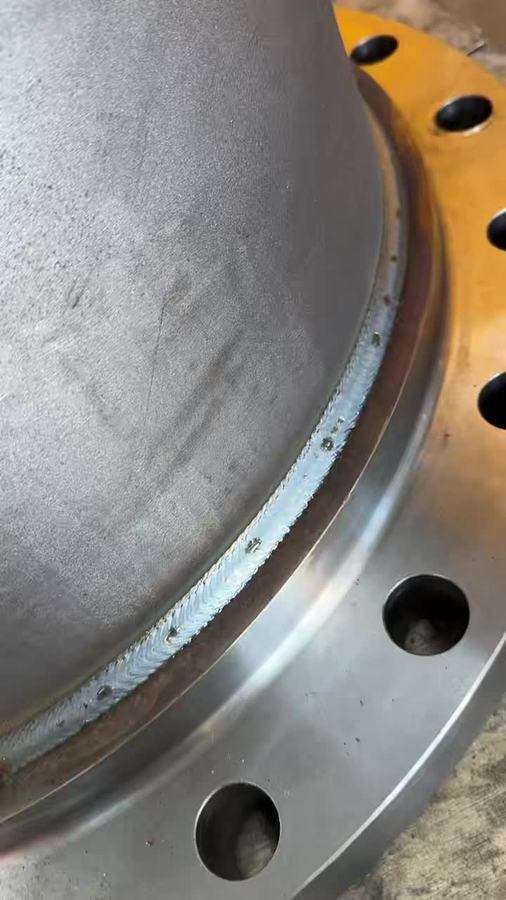
Flange joint weld reference |
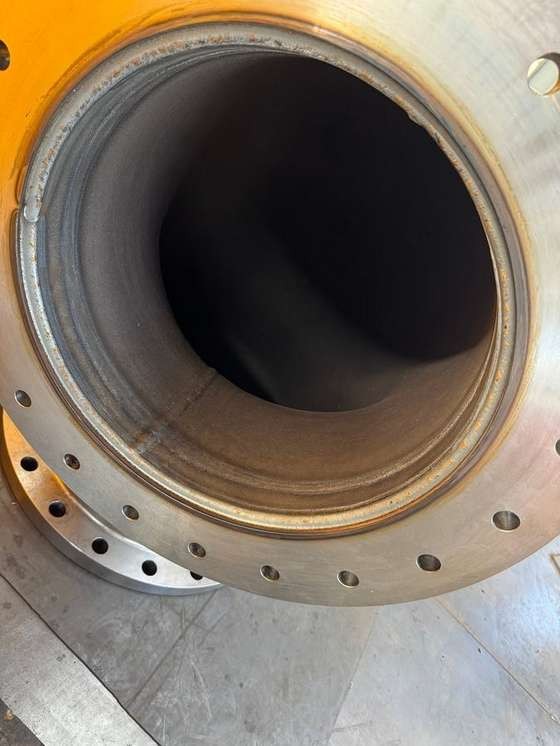
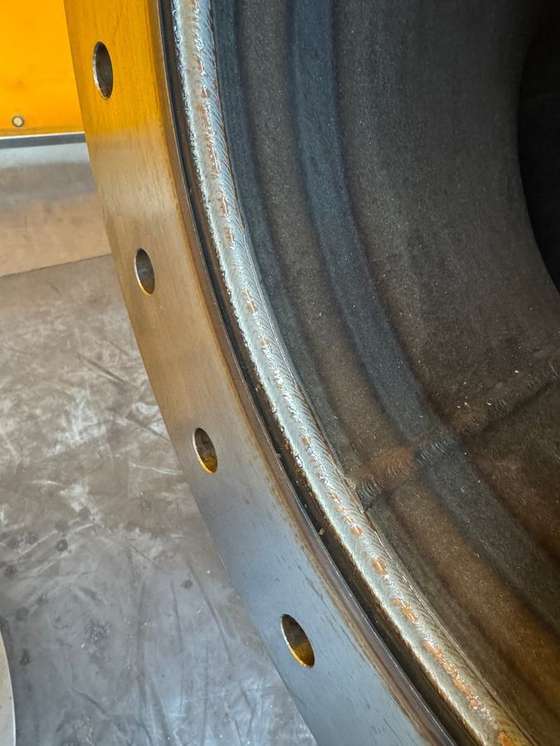
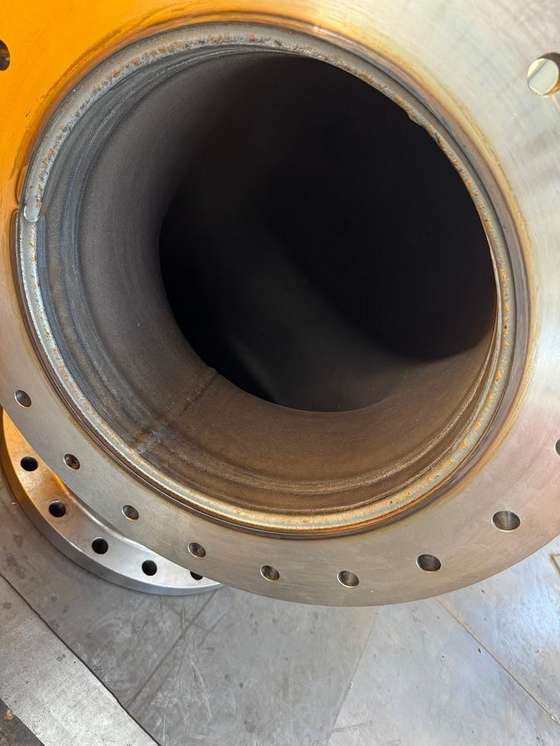
Internal flange weld reference |
Detail of the flange-to-elbow joint |
haibao robot · PRESSURE VESSEL PRODUCTION EQUIPMENT
Robotic Welding for Flanged Elbows and Cooling Pipe Fittings
The haibao robot flanged-elbow cell brings circumferential seams, flange joints and lifting-lug welds into a coordinated fixture and robot sequence. Its reference installation at Jiangyin Dongxin serves pipe fitting production, including cooling-pipeline applications.
Reduce repeated turning and re-clamping
An L-type positioning arrangement presents the required joints to the robot. The fixture and program are developed around the elbow, flange and lug geometry so that compatible welds can be completed in the same clamping arrangement. A dual-station concept can overlap loading and welding where the guarded layout permits.
Welding package and motion
The reference configuration uses a FANUC M-10iD/8L robot with a 2,038 mm maximum reach, R-30iB controller, PM500 power source, VR11000 feeder and TBI 82W torch. Robot reach is only one selection factor; the full fixture, torch and workpiece clearance must be checked.
Locating and tracking
The described arc-welding package includes touch sensing and arc tracking. These functions help correct position variation within validated limits. Consistent fit-up, correct consumables and a suitable procedure remain necessary, especially for thick-wall multi-pass joints.
Estimate the complete cycle
The source reference gives a 400 mm/min average travel speed for a 16 mm carbon-steel application. A 9,700 mm travel length corresponds to 24.25 minutes of arc travel at that speed. A production estimate must also count passes, repositioning, starts and stops, loading, inspection and changeovers.
Configuration reference
| Workpieces | Flanged elbows, circumferential joints and associated lug welds |
| Reference robot | FANUC M-10iD/8L; maximum reach 2,038 mm |
| Positioning | L-type arrangement; station and load selection by workpiece |
| Welding process | Pulsed gas-shielded welding in the reference application |
| Materials | Carbon steel and stainless steel with separate validated settings |
| Supply scope | Robot, positioning, fixtures, welding package, controls and guarding as agreed |
Discuss your application
Send pipe diameter, wall thickness, elbow and flange drawings, material, lug locations, weld requirements and batch volume. Request a fixture layout and full-cycle estimate for your part family.
haibao robot
Shao Yicheng · Key Account Project Director · International Welding Engineer (IWE)
Email: masterhyper@163.com
Phone / WhatsApp: +86 177 5158 3908
Office: +86 519 8837 0688
Explore welding and cutting equipment · Read more application stories
INQUIRY
Categories
Latest News
Contact Us
Contact: Mr.Shao
Phone: 0086-17751583908
E-mail: 691043690@qq.com
Whatsapp:86-17751583908
Add: shanghai, China TianHe District, GuangZhou Num 899