News
Dual-Robot Steel Truss Welding Cell | haibao robot
Equipment and application images
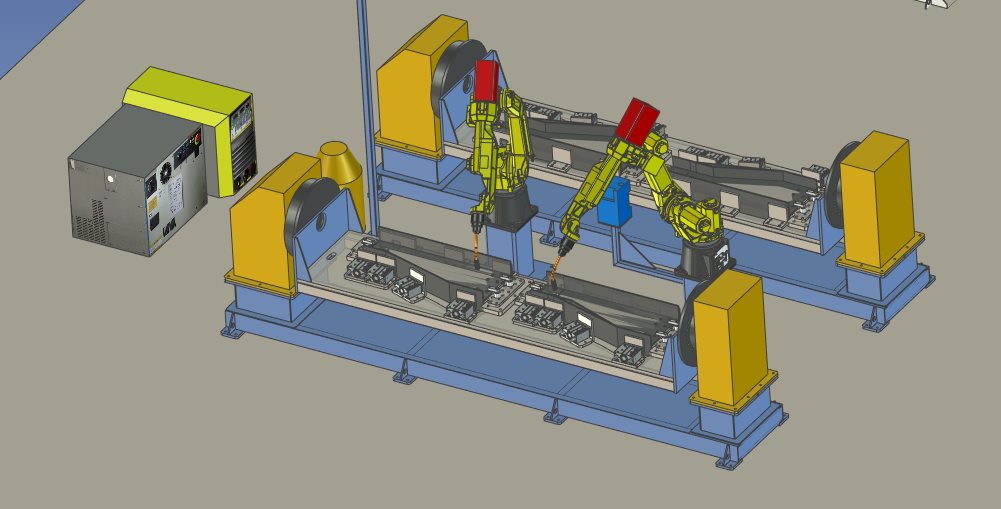
3D layout of the dual-robot steel truss welding cell |
Headstock, tailstock and distributed clamping fixture layout |
Two robots welding a supported steel truss |
Workshop view of structural steel robotic welding cells |
Steel truss joint and weld detail |
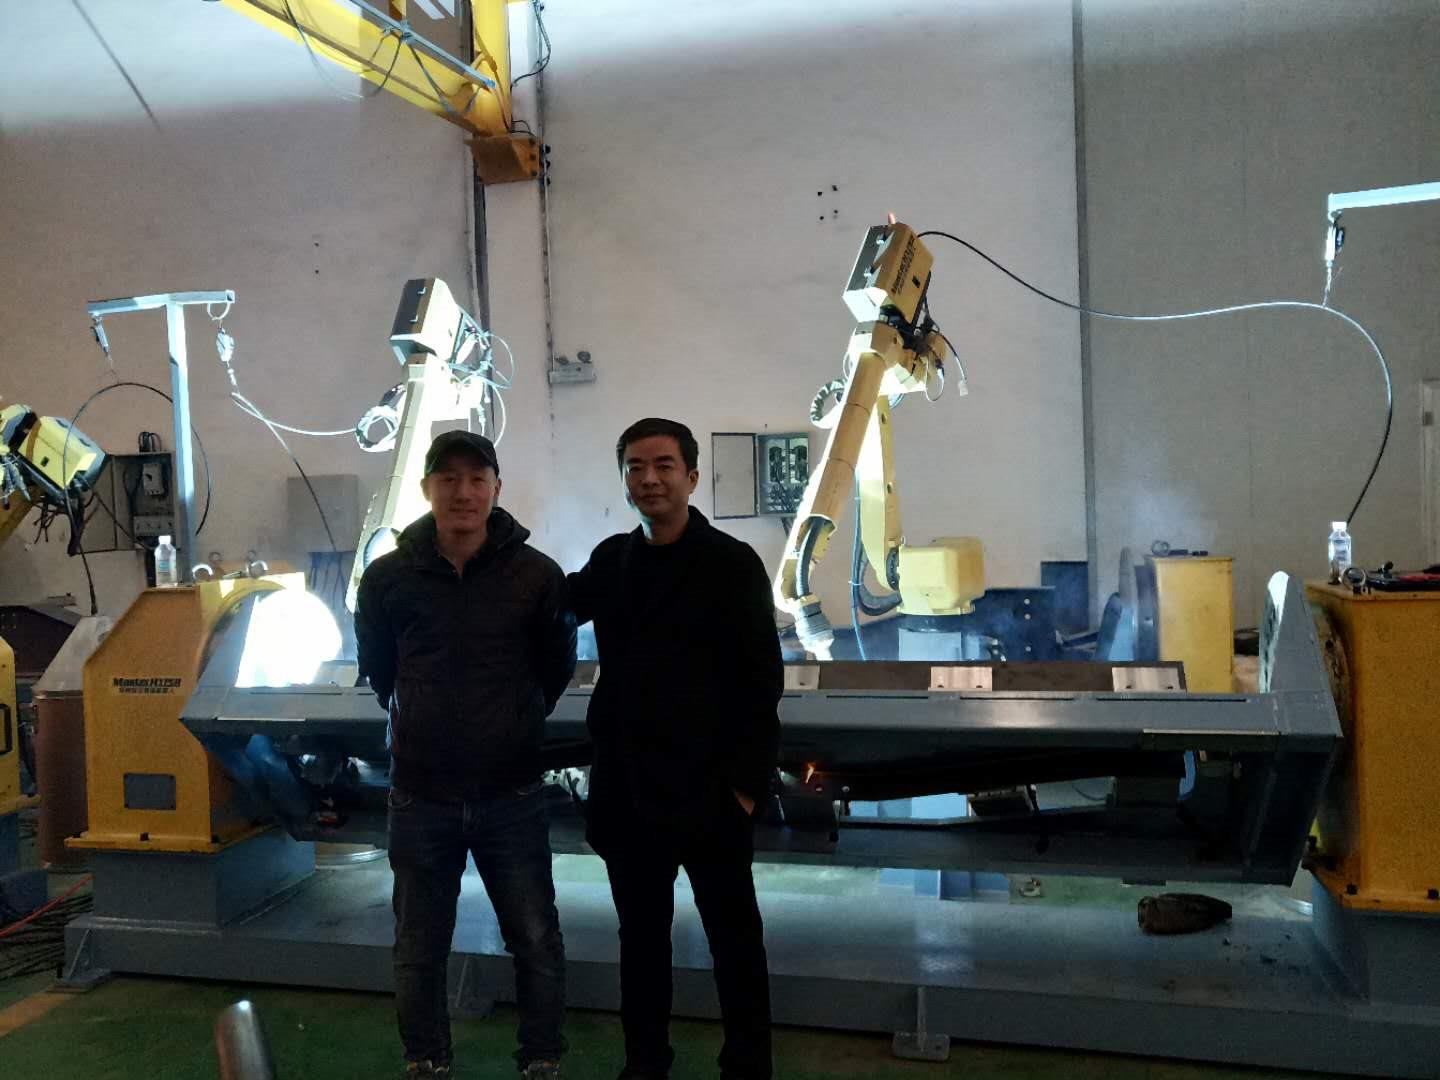
Team at the installed truss welding cell |


haibao robot · NEWS & TECHNICAL INSIGHTS
Two Robots and Two Turning Positioners for Steel Truss Welding
A steel truss welding cell must coordinate torch access with workpiece support, clamping and turning. This haibao robot installation combines two FANUC M-10iD/8L robots with two long turning fixtures for structural steel trusses.
The cell layout
The two robots are positioned between the fixture assemblies. Headstock and tailstock supports carry the long workpieces, while distributed clamps locate the structural members along their length. The arrangement links robot reach to the locations and orientations of the required welds.
Welding and turning in one sequence
Turning positioners reorient the truss so the planned joints can be approached by the torch. Robot task allocation, motion order and collision avoidance are coordinated with the turning positions. Fixture design must preserve access to the welds while maintaining repeatable location.
Three checks before production
First, verify the workpiece datums and clamps. Second, check turning clearance and robot access throughout the program. Third, validate the welding procedure against material, thickness and joint requirements. These checks connect the 3D layout to the actual fabrication task.
Assess the full production cycle
Loading, clamping, turning, welding and inspection all contribute to output. The photographs and layout views show the installation and workshop context; they do not establish a universal capacity or cycle time. Workpiece range, positioner load and process settings are determined from the project drawings.
Discuss your application
Send truss drawings, overall dimensions, weight, material, member thicknesses, weld requirements and production batch sizes. We will review robot configuration, turning method and cell layout.
haibao robot
Shao Yicheng · Key Account Project Director · International Welding Engineer (IWE)
Email: masterhyper@163.com
Phone / WhatsApp: +86 177 5158 3908
Office: +86 519 8837 0688
Explore welding and cutting equipment · Read more application stories
RELATED NEWS
- 3D Laser Cutting for Fitness Equipment Frames | haibao robot 2026-11-01
- Automated 3D Laser Trimming for Hot-Stamped Steel | haibao robot 2026-11-01
- Laser Trimming and Hole Cutting for Bent Tubes | haibao robot 2026-11-01
- Large-Format 3D Laser Cutting for Long Metal Parts | haibao robot 2026-11-01
- 3D Laser Cutting for Hydroformed Automotive Tubes | haibao robot 2026-11-01
Categories
Latest News
Contact Us
Contact: Mr.Shao
Phone: 0086-17751583908
E-mail: 691043690@qq.com
Whatsapp:86-17751583908
Add: shanghai, China TianHe District, GuangZhou Num 899