News
Pipe Flange & Elbow Welding Robot | haibao robot
Project photographs and equipment references
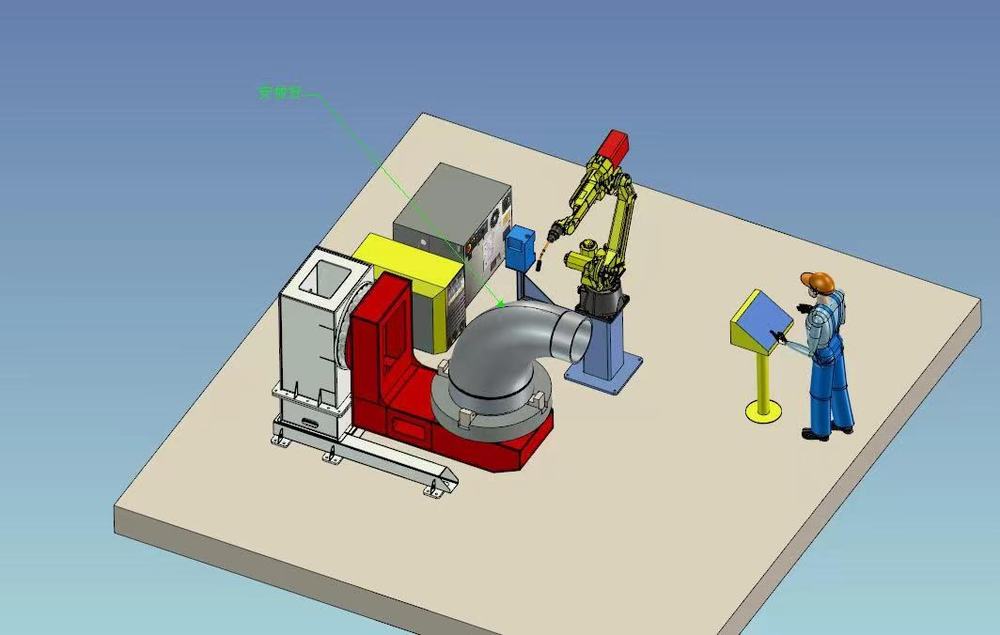
3D concept layout of the robot and L-type positioner |
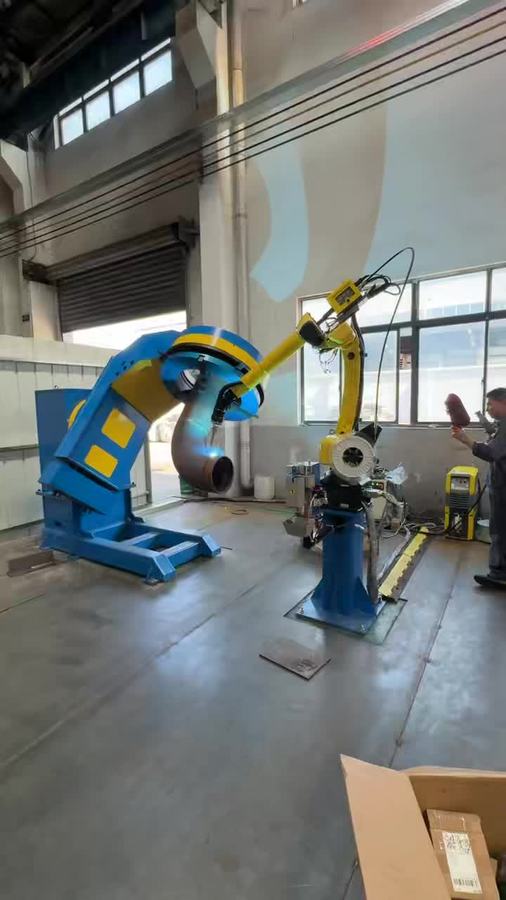
Robot welding cell and workpiece positioner |
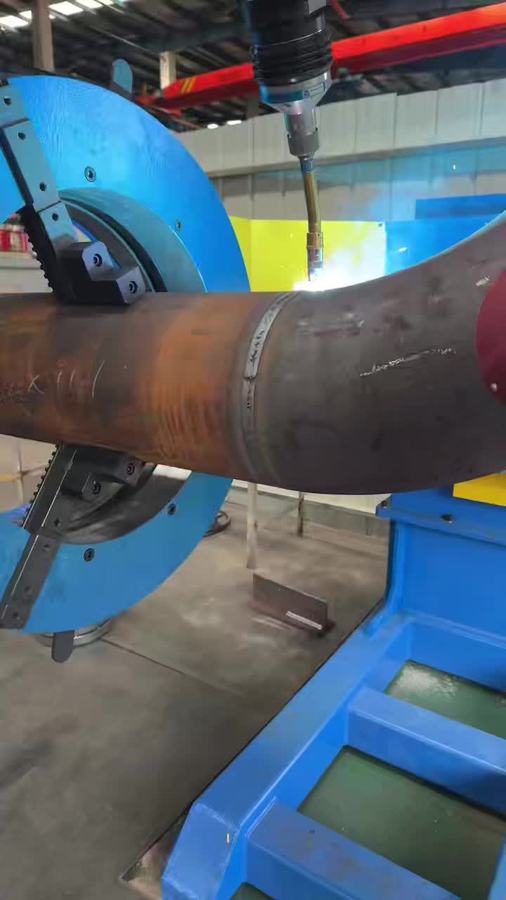
Robotic circumferential welding in progress |
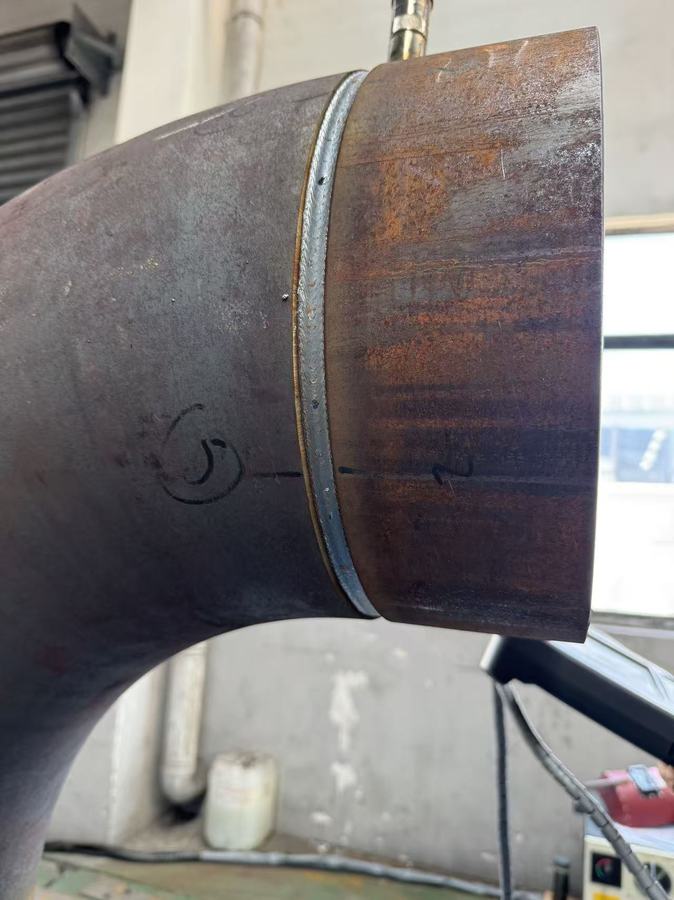
Elbow and flange circumferential weld |
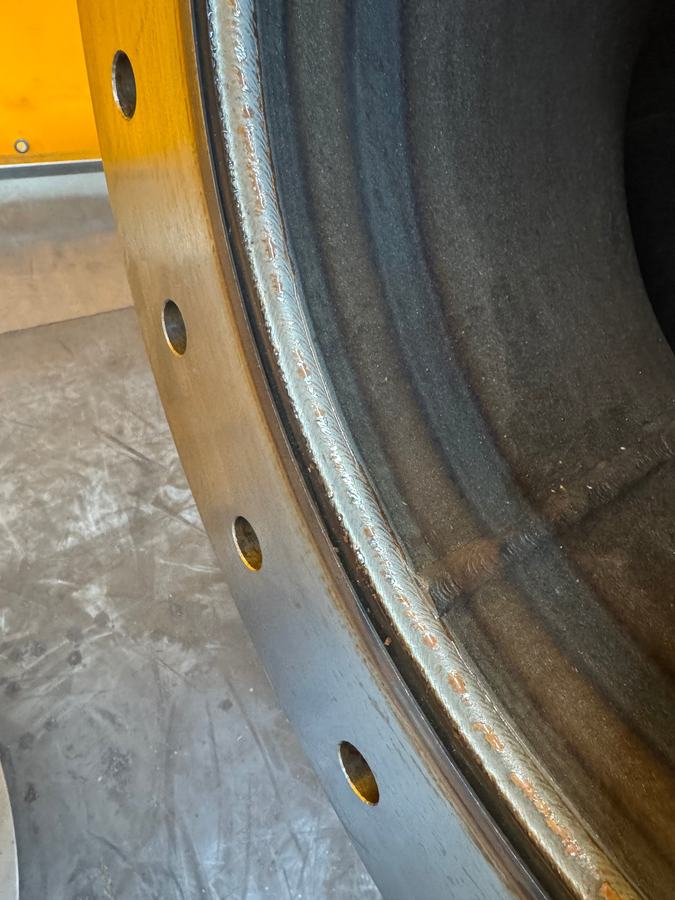
Flange-to-pipe weld detail |
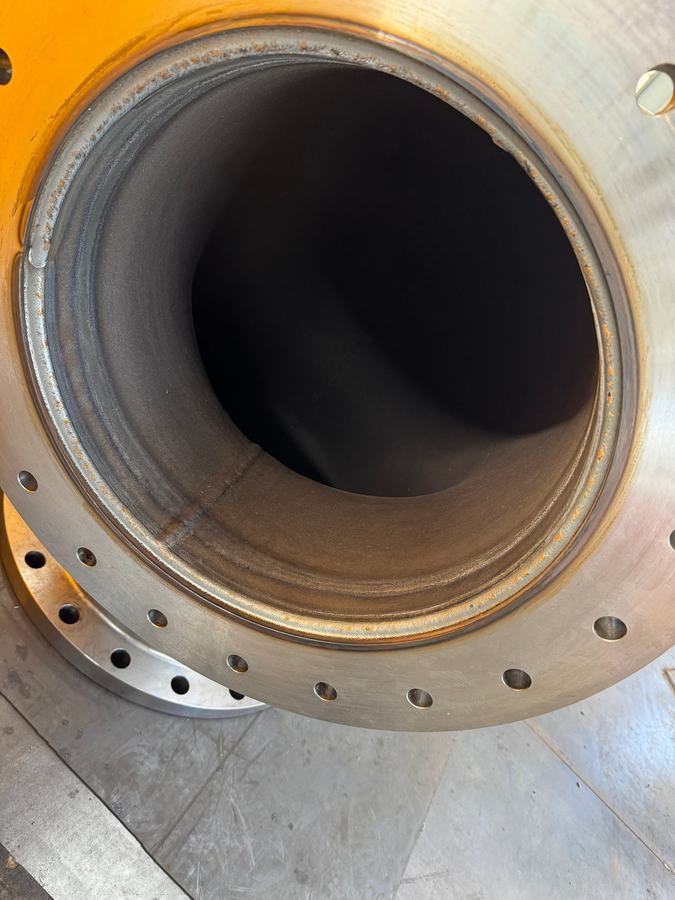
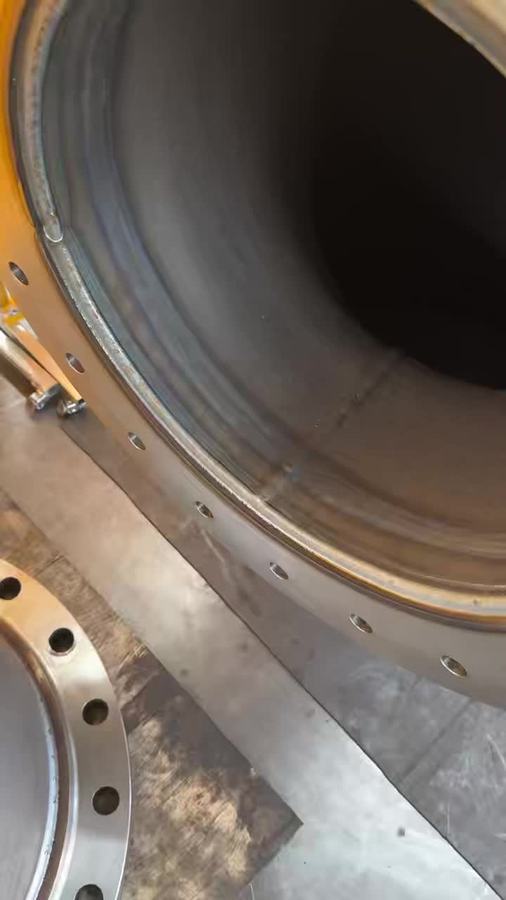
Internal bore and weld root |
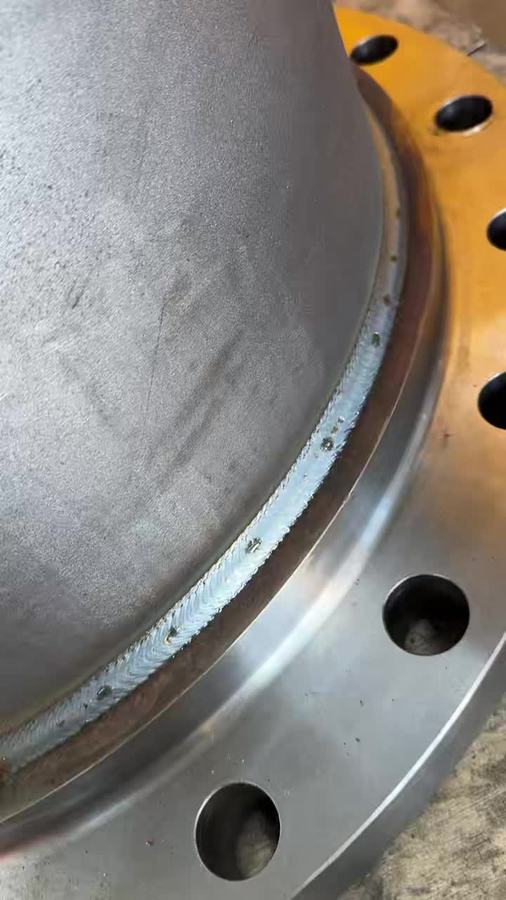
Close-up of the flange joint |
Flange face and internal wall |
haibao robot · CUSTOMER APPLICATION
Robotic Welding of Flanged Elbows for Cooling-Water Systems
Large flanged elbows combine long circumferential seams, thick flanges and welds around lifting attachments. haibao robot developed a coordinated robot and L-type positioner cell for this mix of joints in cooling-water pipework.
The workpiece challenge
The flange and pipe wall have different thicknesses, making heat input and distortion control important. Long seams require repeatable torch access, while flange sealing faces must be protected from spatter and handling damage. Incoming fit-up variation also needs to be addressed before starting the weld.
Cell configuration
The documented system uses a FANUC M-10iD/8L robot with a 2,038 mm reach, an R-30iB B-CAB controller and a dual-station L-type turning positioner. Welding equipment includes a PM500 power source, VR11000 wire feeder and German TBI 82W torch with hollow-wrist routing. Controls, alarms, clamping components and guarding are integrated into the cell.
Touch sensing and seam tracking
Wire touch sensing establishes workpiece reference positions before welding. Through-arc seam tracking adjusts the path during weaving to compensate for position changes. Multi-layer, multi-pass programs control the sequence for thicker joints, with torch cleaning and wire trimming included in routine operation.
From loading to the next station
Lift the elbow into the fixture, locate and clamp it, select the matching program and check shielding gas and wire. The robot then performs sensing, root welding and subsequent passes while the positioner presents the joint. After completion, the system returns to its changeover position for the next workpiece.
Assess cycle time from the actual drawing
The source example gives 400 mm/min average welding speed and 9,700 mm of weld length, corresponding to 24.25 minutes of travel at that speed. This is a weld-travel calculation, not a guaranteed total production cycle: loading, sensing, pass count, cleaning and inspection must also be included.
Request an application review
Send pipe diameter, wall thickness, material, flange standard, lifting-lug locations, joint drawings and batch size.
haibao robot
Shao Yicheng · Key Account Project Director · International Welding Engineer (IWE)
Email: masterhyper@163.com
Phone / WhatsApp: +86 177 5158 3908
Office: +86 519 8837 0688
RELATED NEWS
- 3D Laser Cutting for Fitness Equipment Frames | haibao robot 2026-11-01
- Automated 3D Laser Trimming for Hot-Stamped Steel | haibao robot 2026-11-01
- Laser Trimming and Hole Cutting for Bent Tubes | haibao robot 2026-11-01
- Large-Format 3D Laser Cutting for Long Metal Parts | haibao robot 2026-11-01
- 3D Laser Cutting for Hydroformed Automotive Tubes | haibao robot 2026-11-01
Categories
Latest News
Contact Us
Contact: Mr.Shao
Phone: 0086-17751583908
E-mail: 691043690@qq.com
Whatsapp:86-17751583908
Add: shanghai, China TianHe District, GuangZhou Num 899